All bites
The whole library, newest first. Filter by what you are here for, or pick a topic if you already know.
8667 bites
Page 391
Harris Corner Detector: Finding Sharp Changes in Images
The Harris detector finds corners by looking for points where image intensity changes sharply in all directions. It's used in image stitching and object tracking to find stable feature points. A key weakness is its sensitivity to image scale.
Laplacian of Gaussian (LoG) for Blob Detection
LoG finds blobs by blurring an image then finding points of maximum curvature, like finding the top of a hill by looking where the slope changes fastest. It's used in medical imaging and astronomy. The footgun: the blur size dictates the blob size you can.
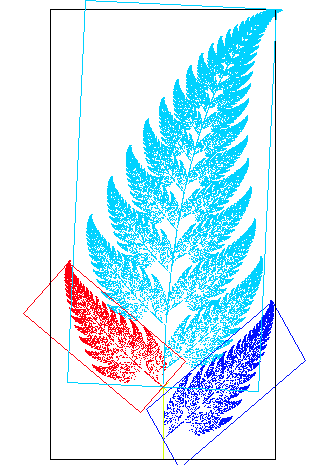
Affine Transformations: Move, Scale, and Rotate Without Bending
An affine transformation is a way to move, scale, rotate, or shear an object while keeping all lines straight and parallel lines parallel. It's used everywhere in computer graphics.
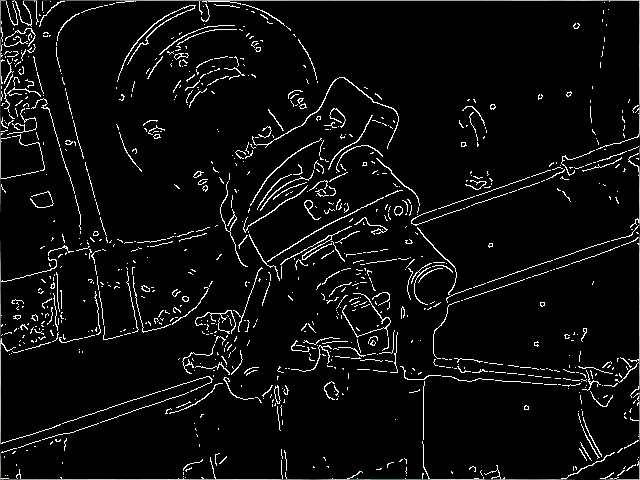
Canny Edge Detector: Finding True Edges
The Canny detector finds true edges by identifying sharp, connected intensity changes. It's used in object detection and feature extraction where clean edge maps are vital.
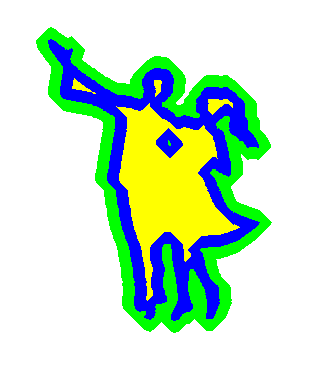
Morphological Transformations: Shaping Images with Kernels
Think of it as sanding or stamping an image with a small shape (kernel) to modify object boundaries. It's used for noise removal or separating touching objects. The footgun: transformations alter object size, so you often need a second operation to compensate.
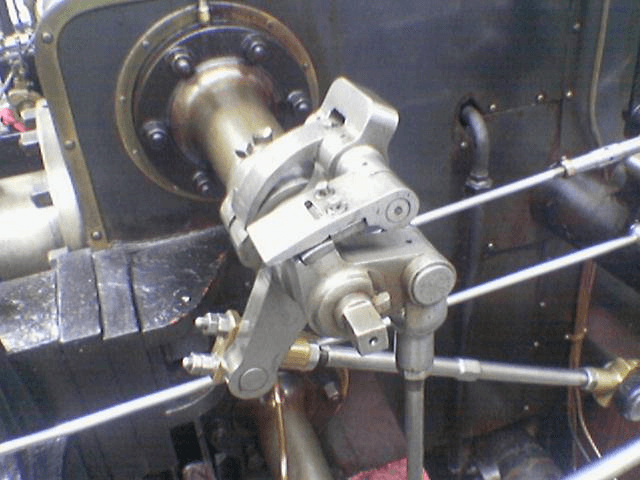
The Sobel Operator: Fast, Cheap Edge Detection
The Sobel operator finds image edges by measuring how fast pixel brightness changes horizontally and vertically. It's a fast, cheap first pass for edge detection in computer vision. The footgun is treating it as precise; it's a crude approximation.
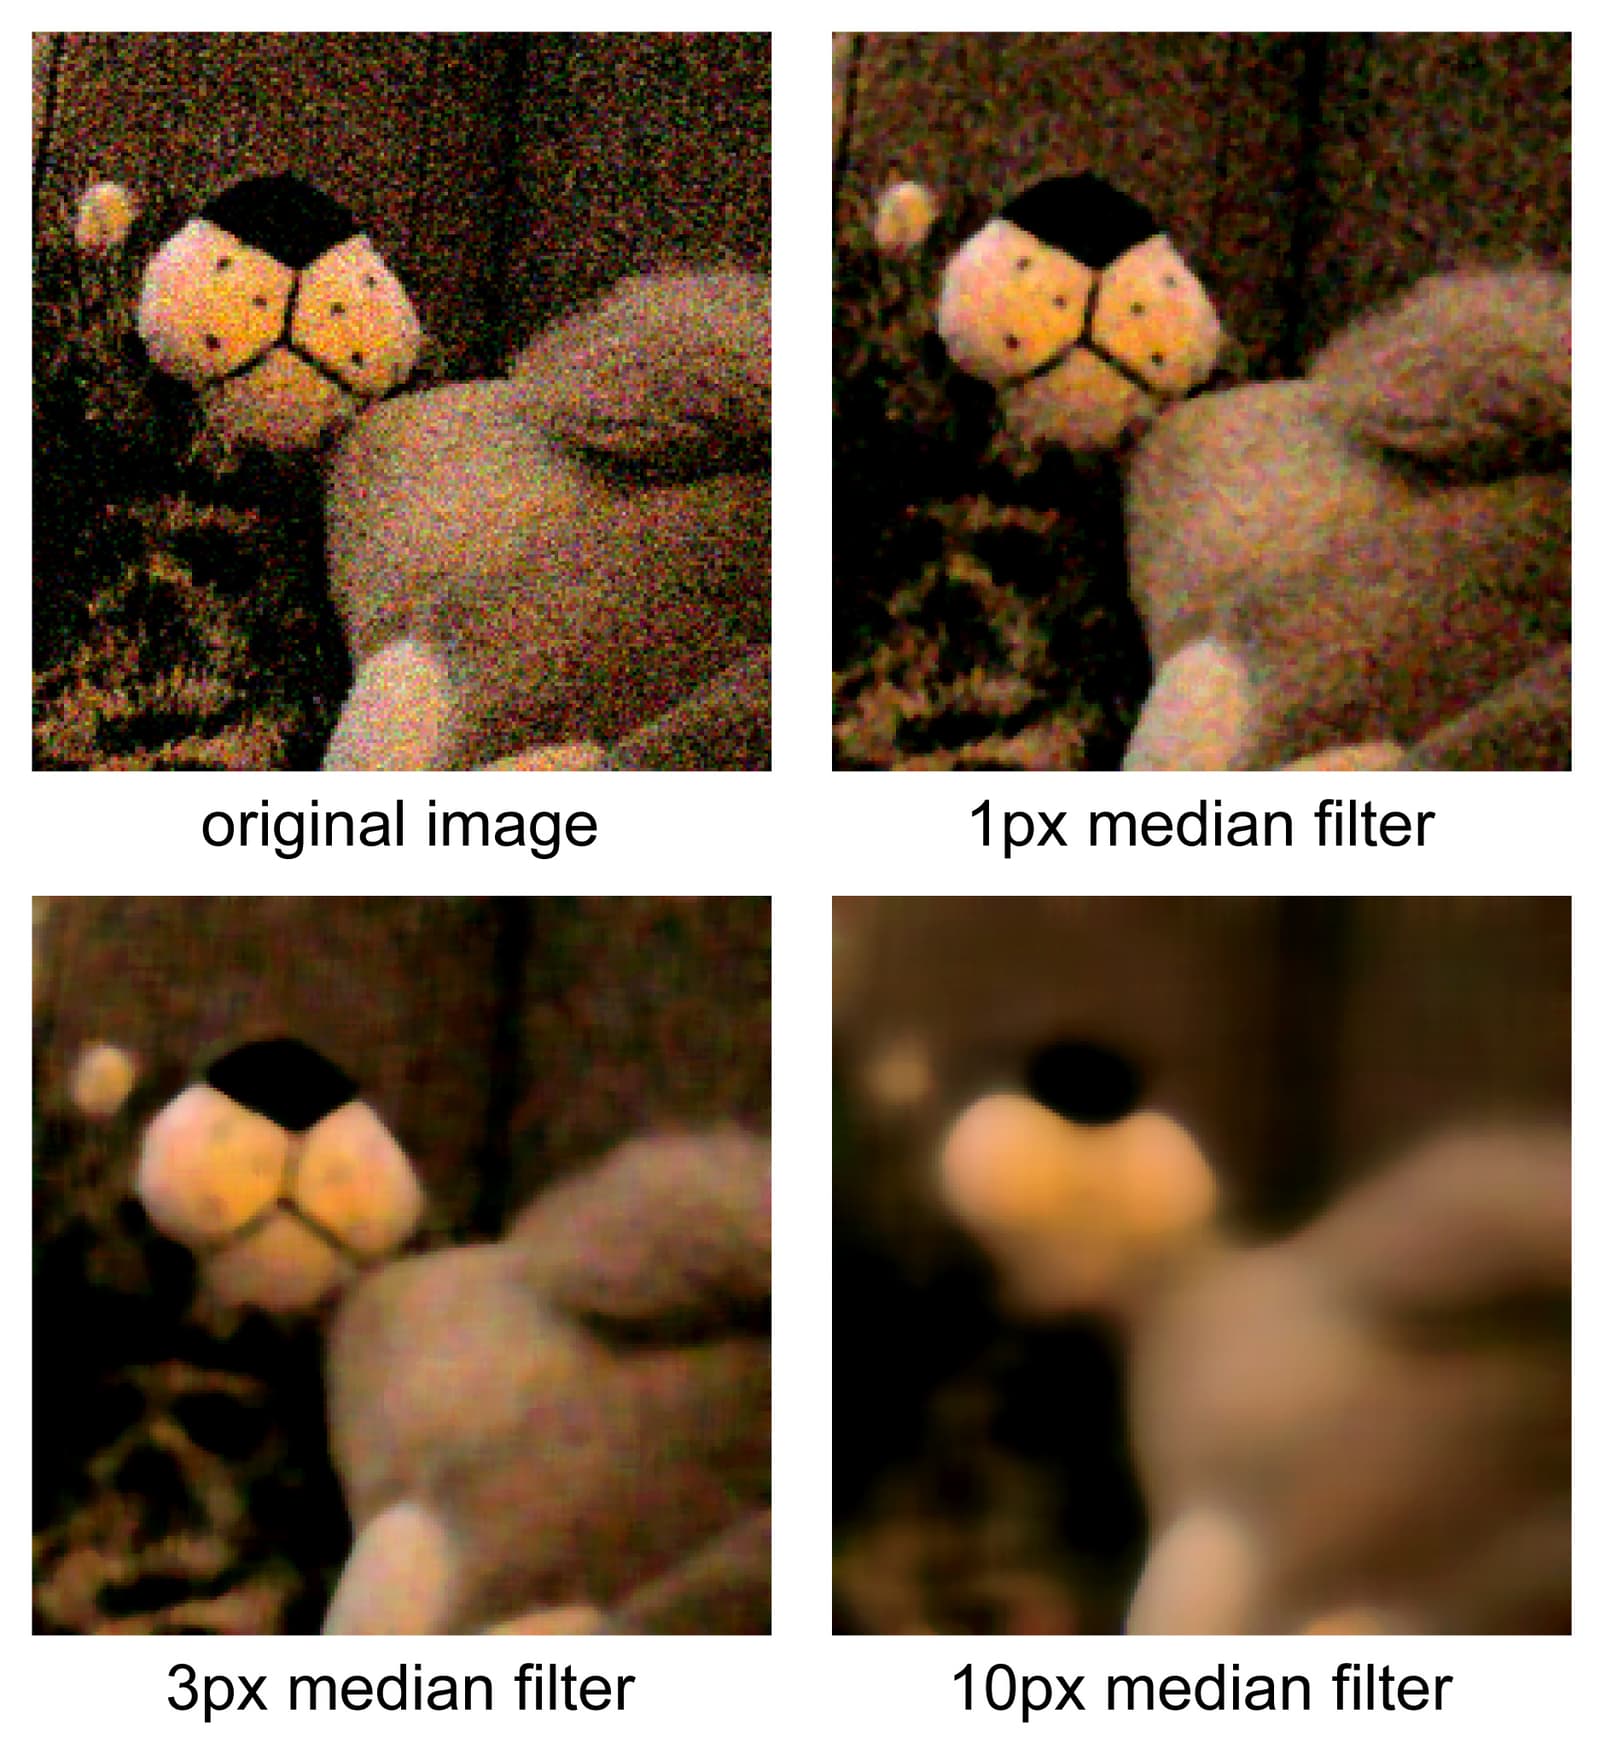
Median Filter: Smoothing Images Without Blurring Edges
A median filter cleans image noise by replacing each pixel with the median value of its neighbors, ignoring outliers. It's used to remove "salt-and-pepper" noise before object detection.

Gaussian Blur: Smoothing Images with Weighted Averages
Gaussian blur smooths an image by replacing each pixel with a weighted average of its neighbors, where closer pixels matter more. It's used to reduce noise before edge detection or for UI effects. The footgun is over-blurring, which erases important features.
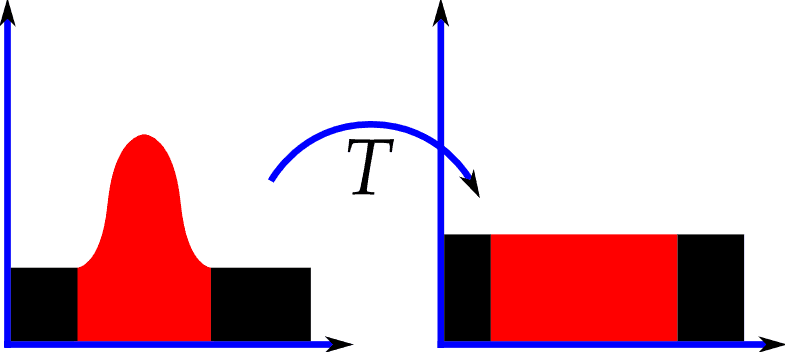
Histogram Equalization: Spreading Out Pixel Brightness
Think of histogram equalization as automatically stretching an image's contrast. It takes dark or washed-out images and spreads their pixel brightness values across the full available range, revealing hidden details. The footgun: it can amplify noise.

Image Scaling: Resizing Pixels Without Ruining Them
Image scaling isn't just stretching a picture; it's inventing or discarding pixel data. It's used everywhere from displaying thumbnails to making 1080p video fit a 4K screen.
Grayscale Conversion: Seeing in Shades of Gray
Grayscale conversion simplifies an image by removing color, representing each pixel's brightness as a single value. It's a key preprocessing step in computer vision for tasks like OCR, where shape matters more than color.

Bayer Filter: Faking Full Color with a Filter Grid
A Bayer filter is a hack for capturing color with one sensor: a checkerboard of red, green, and blue filters is placed over the sensor grid. This is how most digital cameras work. The footgun is that the raw output must be 'demosaiced' to create.

BRDF: Modeling How Surfaces Reflect Light
A BRDF is a function that describes a surface's appearance by defining how it reflects light from any incoming direction to any viewing direction. It's used in rendering engines to create materials like brushed metal or velvet.

Radiometry: Measuring Light as Physics, Not Perception
Radiometry measures light's physical power, not how humans perceive it. It's for objective energy measurement in computer vision or physics simulations, using watts, not lumens. The footgun is confusing it with photometry, which is weighted for human vision.
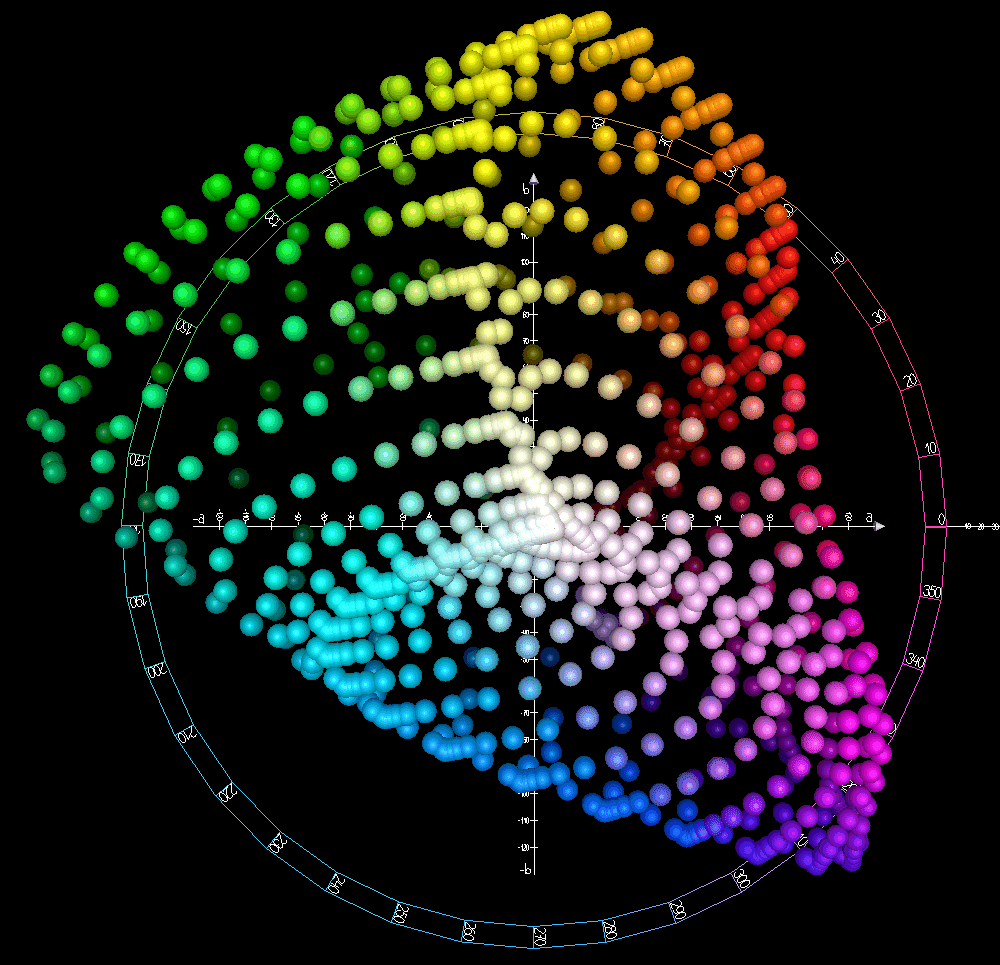
CIELAB Color Space: Measuring Color Beyond RGB
CIELAB models color not by how a screen displays it (like RGB), but by how a human perceives it: lightness, red/green, and yellow/blue. It's used in industry to measure and match colors precisely. The footgun is assuming it's perfectly 'perceptually uniform'.
Color Depth: Bits Per Pixel vs. Bits Per Channel
Color depth is the number of bits storing a pixel's color, like a digital paint box's size. It's key for image formats and displays, affecting file size and fidelity. The footgun is confusing total bits per pixel (bpp) with bits per channel (bpc).

HSL and HSV: Intuitive Ways to Represent RGB Color
HSL and HSV are not new colors, but new ways to organize RGB. Think of them as cylindrical coordinates for color, making it easier for humans to select shades. You see them in every color picker.
Lens Distortion: Why Straight Lines Curve in Photos
Lens distortion makes straight lines appear curved in an image, a result of imperfect lens geometry. It's critical to correct in computer vision for tasks like 3D reconstruction, but is often ignored in regular photography.
Camera Resectioning: Finding a Camera's Pose in 3D Space
Camera resectioning is like a detective's trick: use a photo of known objects to find the exact 3D position and orientation of the camera. It's key for AR and robotics. The footgun is assuming this finds all camera flaws; it only finds pose, not lens.
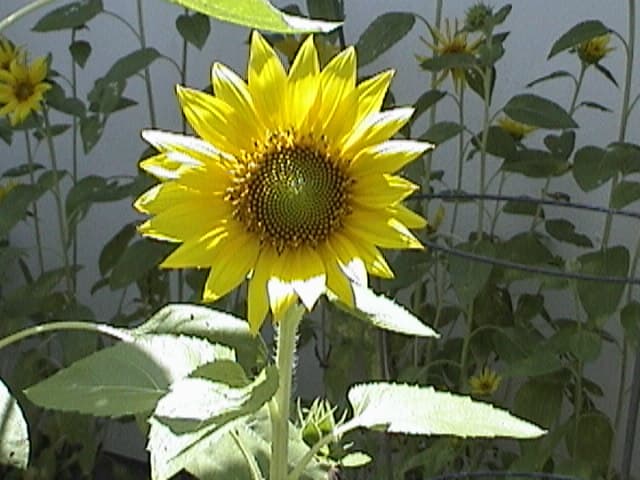
Image Histograms: Visualizing an Image's Tonal DNA
An image histogram is a bar chart of an image's brightness, showing pixel counts from pure black to pure white. It's used in photo editing to instantly judge exposure, revealing clipped shadows or blown highlights.