Intermediate everything in AI & ML, page 27

3D Object Detection: Seeing in Depth, Not Just Pixels
3D object detection adds depth to a 2D flat view, understanding an object's true size, distance, and orientation. It's vital for autonomous cars and robotics that need spatial awareness.
Semantic Scene Classification: Understanding Context, Not Just Objects
Scene classification tells you the context of an image ("this is a forest"), not just the objects in it ("there's a tree"). It's used by self-driving cars to identify a highway vs. a residential street and by apps to organize photos.
Autoregressive Models: Generating Images One 'Word' at a Time
Autoregressive models generate images sequentially, like writing a sentence word by word. Each new pixel or patch depends on what came before. This creates high-fidelity images but is much slower than one-shot models, a key trade-off in generative AI.
Self-Attention: How Models Weigh Word Importance
Self-attention lets a model weigh the importance of all words in a sequence simultaneously, asking "which other words are most relevant?" It's the core of Transformers, enabling parallel processing for tasks like translation, unlike sequential RNNs.
U-Net: Encoder-Decoder for Image Segmentation
U-Net segments images by first compressing them to capture context, then expanding to localize features precisely. It excels in biomedical imaging where annotated data is scarce.
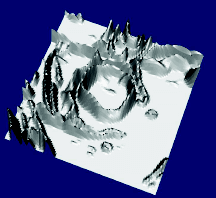
Watershed Algorithm: Segmenting by Topography
The watershed algorithm treats an image as a landscape where pixel brightness is height. It finds the 'ridges' separating distinct 'valleys,' effectively segmenting touching objects. Its main footgun is extreme sensitivity to noise, causing over-segmentation.
Anchor Boxes: Pre-defined Guesses for Object Detection
Anchor boxes are predefined 'template' boxes of various sizes and shapes. Object detection models use them as a starting point, predicting how to shift and scale these templates to fit actual objects, making detection faster.
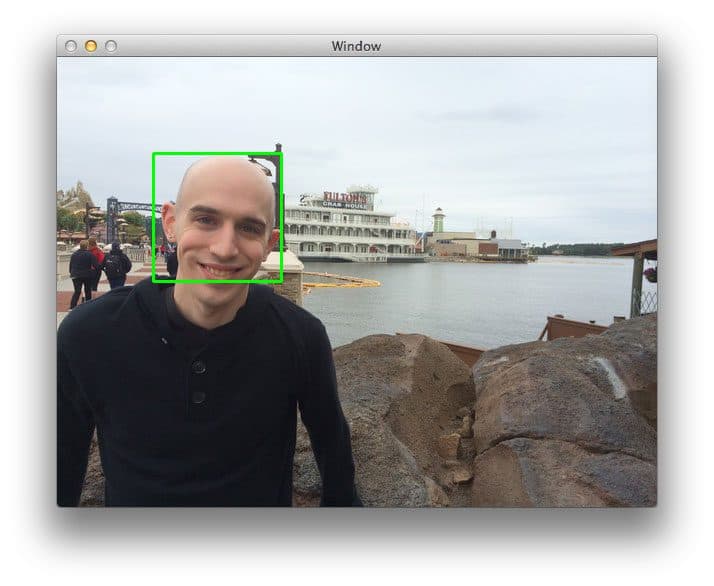
Sliding Windows: Scanning Images for Objects
A sliding window scans an image with a fixed-size box to find objects. At each location, a classifier checks the window's contents. Combined with an image pyramid, it can detect objects at various scales, localizing exactly where they are.
BRIEF: Fast, Compact Binary Feature Descriptors
BRIEF describes image features as a compact binary string instead of a complex vector. This makes it extremely fast for real-time matching on low-power devices. The footgun: its raw form isn't rotation-invariant, trading that robustness for raw speed.

Perspective Transformation: Making 3D Look Right on a 2D Screen
Perspective transformation is like looking through a camera lens; it makes distant objects smaller to create the illusion of depth on a flat screen. It's essential for 3D games and computer vision.
Image Thresholding: Separating Foreground from Background
Image thresholding turns a grayscale image into black and white by setting a brightness cutoff. It's used to isolate features for analysis, like finding text on a page.
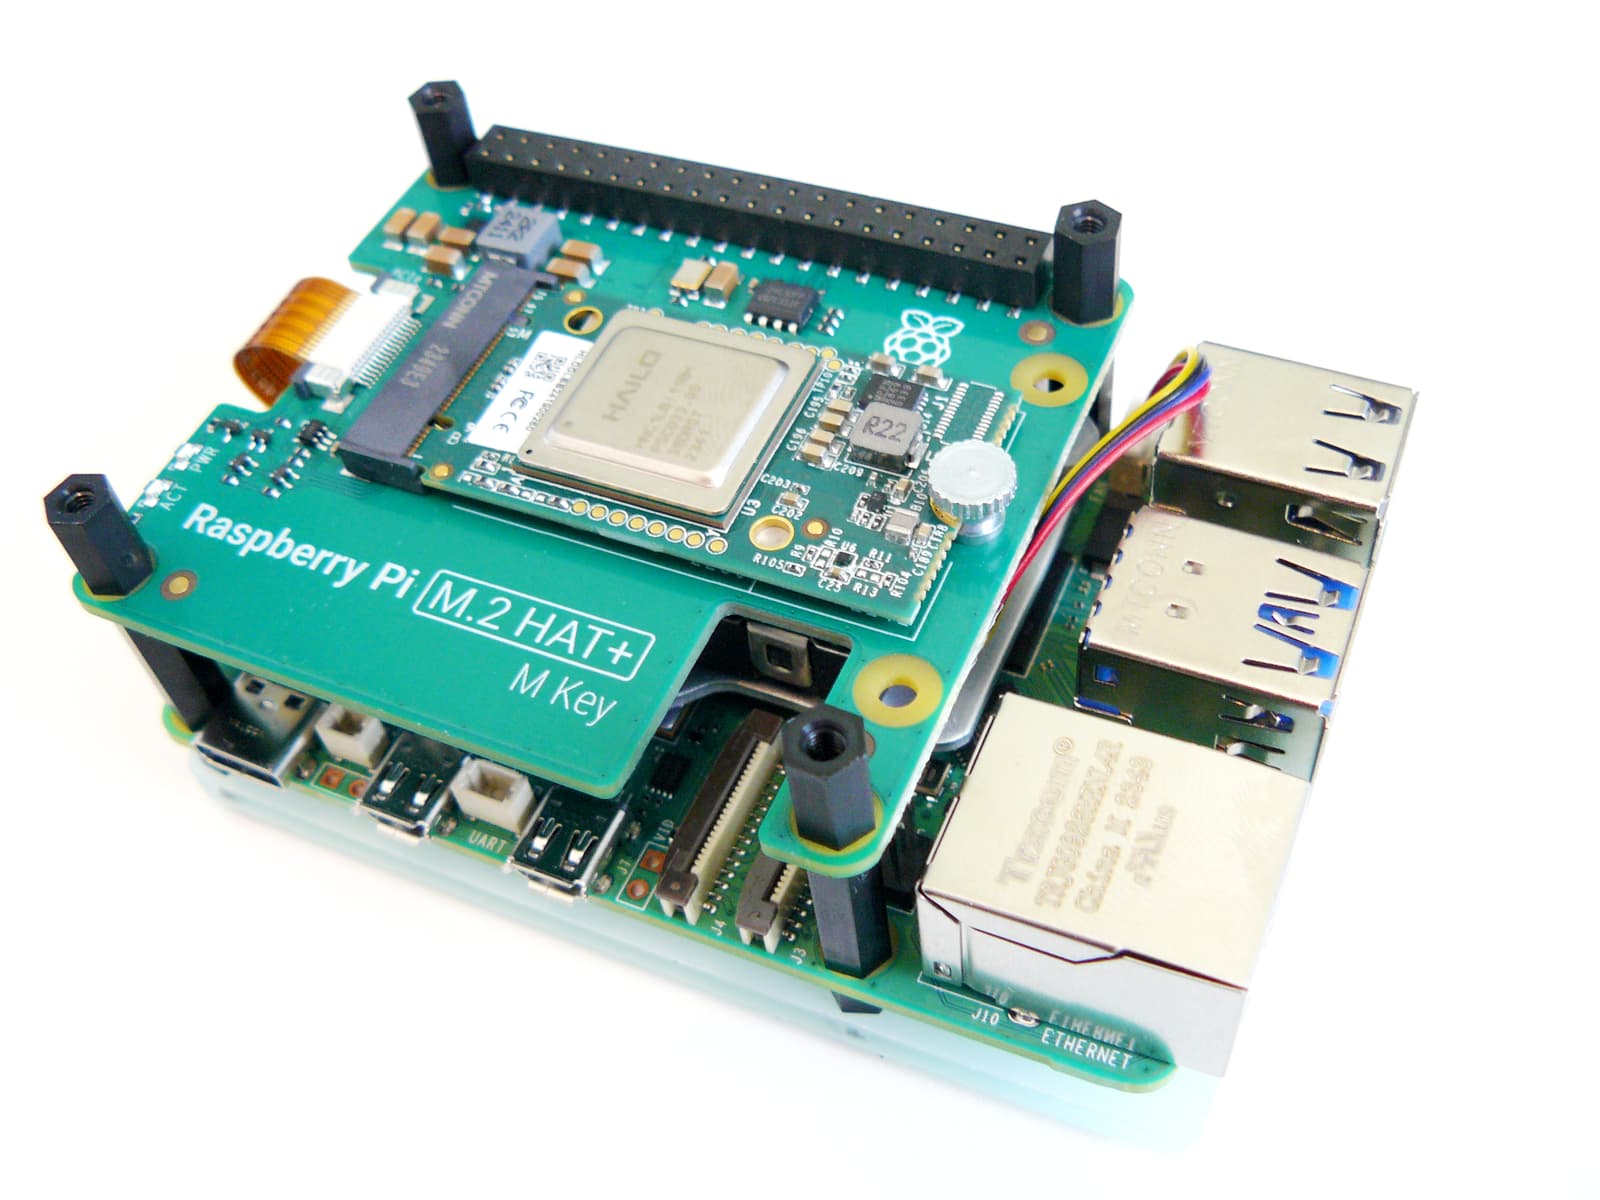
Edge AI Accelerators: Inference Without the Cloud
An Edge AI accelerator is a specialized, low-power chip that runs AI models directly on a device, skipping the cloud. It's used for real-time tasks like object detection where latency and privacy are critical.
ONNX: The Universal Translator for ML Models
ONNX is a universal translator for ML models, letting you train in one framework (like PyTorch) and run in another. It's used to deploy models to diverse hardware without rewriting them.
Model Quantization: Trading Precision for Performance
Model quantization trades numerical precision for a smaller memory footprint. It reduces model weights from high-precision types like fp32 to lower ones like int8 or int4, making large models fit on consumer hardware.
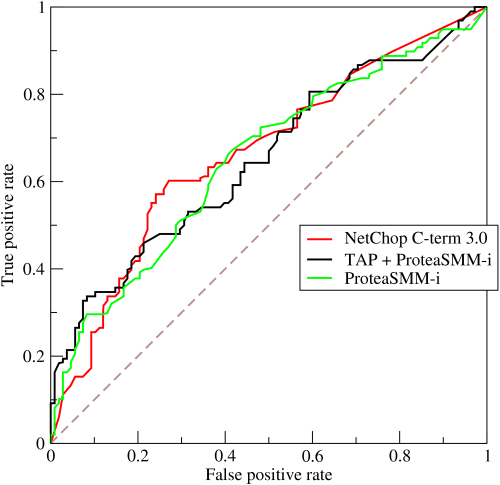
ROC Curve and AUC: Measuring Classifier Performance
An ROC curve visualizes a classifier's trade-off between catching true positives and flagging false ones across all thresholds. It's used to evaluate models like medical diagnostics or spam filters.

Precision vs. Recall: The Classifier's Trade-off
Precision is the quality of your positive predictions; Recall is the quantity you find. A spam filter with high precision avoids false alarms, while high recall catches most spam.
Super-Resolution: Creating Detail from Less
Super-resolution creates a high-res image from low-res sources by inferring missing details. It powers smartphone digital zoom and video upscaling. The footgun: generated details are plausible hallucinations, not ground truth, making it risky for scientific…
Synthetic Aperture: Faking a Big Lens with Software
Synthetic aperture uses depth data to computationally fake the shallow depth-of-field of a large lens. It's the magic behind smartphone 'Portrait Mode,' blurring the background to make a subject pop.
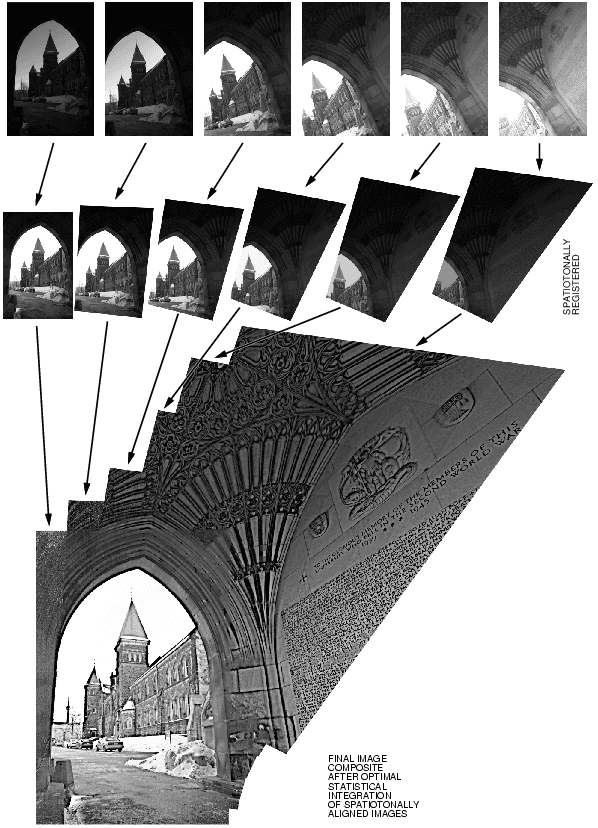
Multi-frame Noise Reduction: Finding Signal in the Noise
Multi-frame noise reduction averages multiple shots to isolate the true signal. The underlying image is consistent, while random noise cancels out. It's key for low-light phone photos and video.
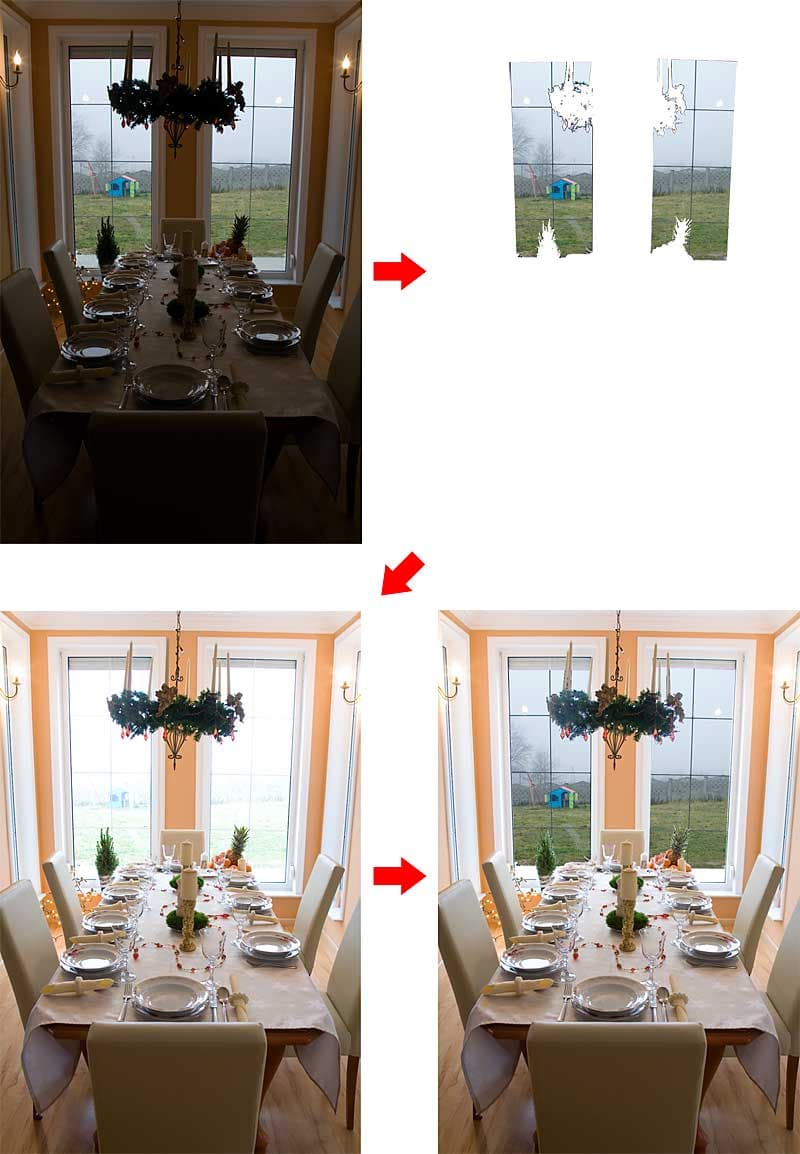
Exposure Fusion: HDR Looks Without the HDR File
Exposure fusion blends the best-lit pixels from several bracketed shots into one image. This lets you capture high-contrast scenes, like a bright window in a dark room, without creating a full HDR file.
We are hiring for this. Every open role lists the topics its interview covers, so you can prepare for the real thing rather than guessing.
See open roles