Everything in AI & ML, page 54
Backpropagation: How Neural Networks Learn from Mistakes
Backpropagation is how a network learns from its mistakes. It works backward from the output error, calculating how much each weight contributed and adjusting it. This is the core training loop for most deep learning models.
Cross-Entropy Loss: How Wrong Is Your Model's Guess?
Cross-entropy loss measures the penalty when a model's predicted probabilities diverge from the true labels. It's the standard loss for classification tasks, like telling a cat from a dog.

ReLU: The 'On/Off' Switch for Neural Networks
ReLU acts as a simple on/off switch for neurons: positive inputs pass through, negative ones become zero. It's the default activation in deep learning, especially for vision tasks, as it's fast and helps gradients flow. The footgun: neurons can "die".
Pooling Layers: Summarizing What Matters in an Image
A pooling layer is like squinting at an image; you lose fine detail but see the main shapes. It summarizes features in a region, reducing computation and making the model robust to small shifts.
Feature Maps: What a Neural Network 'Sees'
A feature map records where a learned filter responds to patterns in its input. In a convolutional neural network, different filters produce different maps. A single map need not represent a whole object; later layers combine information across maps.
Convolutional Layers: Finding Features Anywhere
A convolutional layer is like a flashlight sliding over an image, looking for a specific pattern like an edge or corner. It's the core of computer vision, letting networks find features anywhere.
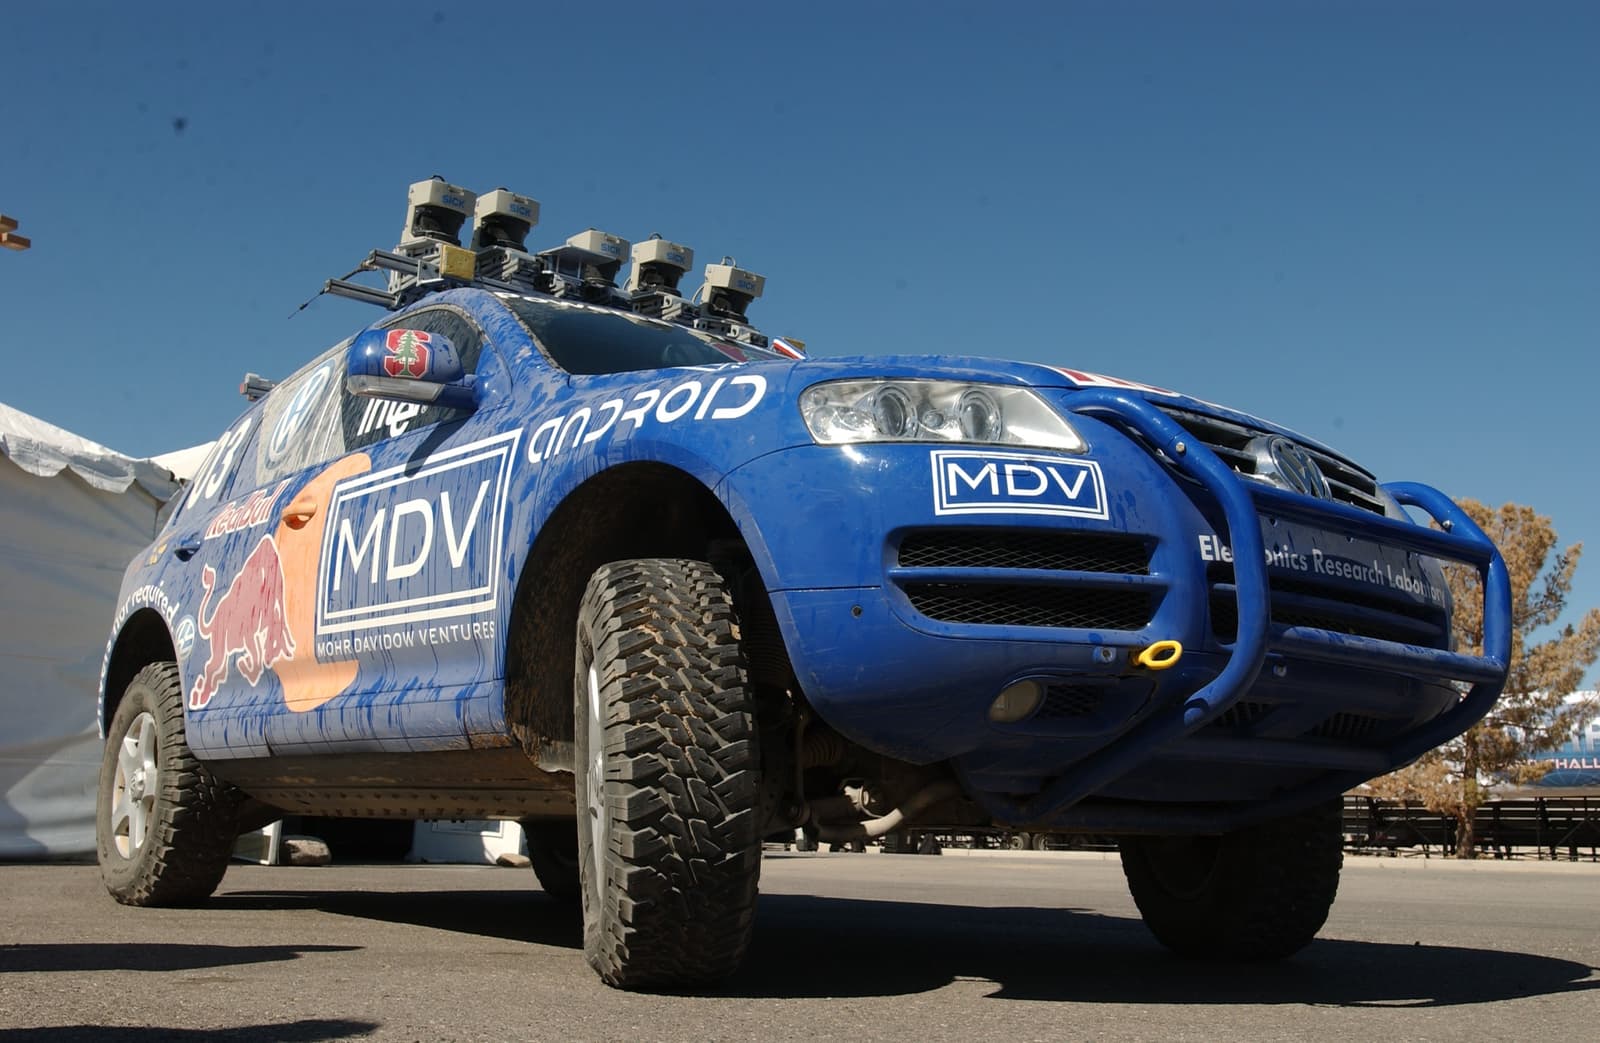
SLAM: Mapping a Room While You're Still In It
SLAM solves a chicken-and-egg problem: you can't map a space without knowing your location, and you can't know your location without a map. It does both at once. It's used by robots and AR headsets to navigate.
Bundle Adjustment: Jointly Refining 3D Scenes and Cameras
Bundle adjustment is a grand negotiation, simultaneously refining a 3D scene, camera poses, and lens properties to best explain the 2D images. It's the final polish in Structure from Motion (SfM) or SLAM.
Eight-Point Algorithm: Finding Geometry from Image Pairs
The Eight-Point Algorithm finds the geometric relationship between two camera views of the same scene. Given at least eight matching points, it estimates the essential or fundamental matrix.
Structure from Motion (SfM): Rebuilding 3D from 2D Photos
Structure from Motion (SfM) reconstructs a 3D scene from 2D images taken from different viewpoints, much like your brain perceives depth. It's used for creating 3D maps from drone footage. The main footgun is its failure on textureless or reflective surfaces.
Triangulation: Finding 3D Points from 2D Images
Like your two eyes judging distance, triangulation finds a point's 3D location by seeing it from two different 2D camera views. It's key for 3D reconstruction and robotics.
The Essential Matrix: Geometry for Stereo Vision
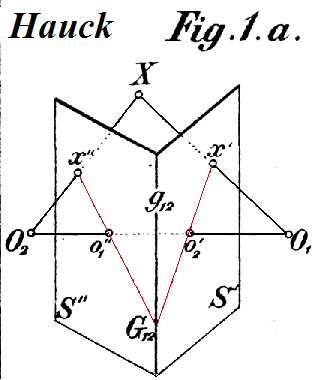
The Essential Matrix is a geometric bridge between two photos of the same scene, encoding the camera's relative motion. It's used in 3D reconstruction to find corresponding points; it tells you where a point from one image must lie in the other.
The Fundamental Matrix: Constraining 3D Search to a Line
The Fundamental Matrix reduces a 2D search for a point in a second image to a 1D search along a line. It's the geometric glue linking two uncalibrated camera views of the same scene, crucial for stereo vision and 3D reconstruction.
Homography: Mapping Flat Surfaces Between Images
A homography is a 3x3 matrix that maps points between two images of a flat surface. It's used for panorama stitching and perspective correction. The footgun: it only works for planes or pure camera rotation, failing on scenes with depth.
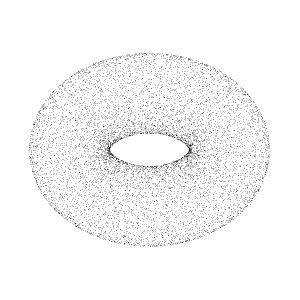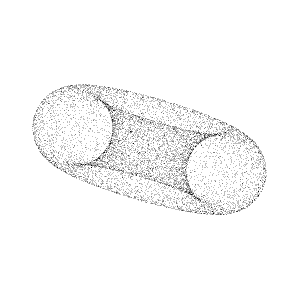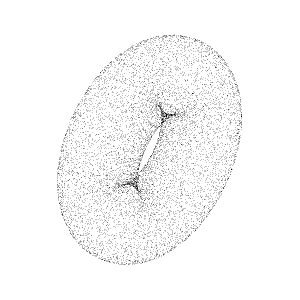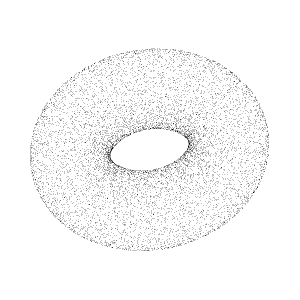
Point Cloud: A 3D Shape as a Dust Cloud of Data
A point cloud represents a 3D object as a cloud of individual data points in space. It's the raw output from 3D scanners, used to create CAD models or GIS maps. The footgun is assuming it's a solid model; it has no surfaces, only disconnected.
Disparity Map: Seeing Depth from Two 2D Images
A disparity map is a grayscale image encoding 3D depth from two 2D images. Brighter pixels mean objects are closer, because they appear to shift more between the left and right camera views. This is key for robotics and autonomous navigation.
The Stereo Correspondence Problem: How Cameras See in 3D
The stereo correspondence problem is how computers see in 3D, like your two eyes. It involves matching the same point in a left and right image to calculate depth. This is key for self-driving cars and robotics. The footgun: textureless walls create ambiguity.

Epipolar Geometry: Finding 3D Points from 2D Images
Epipolar geometry finds a 3D point from two 2D views by constraining the search. Instead of scanning the whole second image for a match, you only look along a single line. It's key for 3D reconstruction. The footgun is assuming perfect pinhole cameras.
Local Binary Patterns (LBP) for Texture Classification
LBP is a 'visual descriptor' that summarizes an image's texture into a feature set for a machine to read. It's a powerful tool for texture classification, but its performance often improves significantly when combined with other descriptors like HOG.
ORB: Fast, Free Feature Detection for Computer Vision
ORB combines the speedy FAST keypoint detector with a rotation-aware BRIEF descriptor. It offers a fast, royalty-free alternative to SIFT for finding and describing unique points in an image, even when the object is rotated.
We are hiring for this. Every open role lists the topics its interview covers, so you can prepare for the real thing rather than guessing.
See open roles